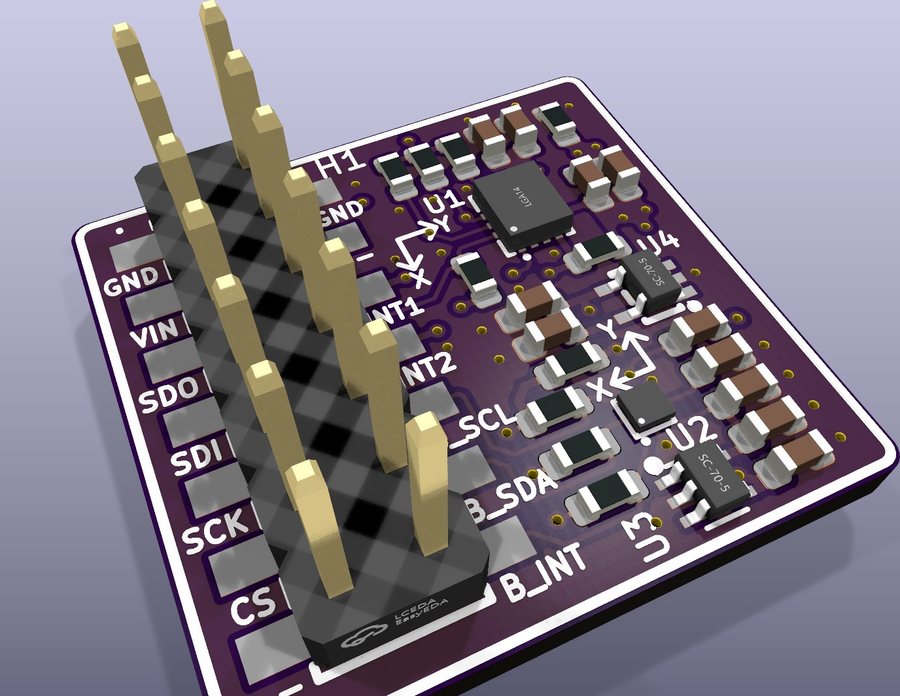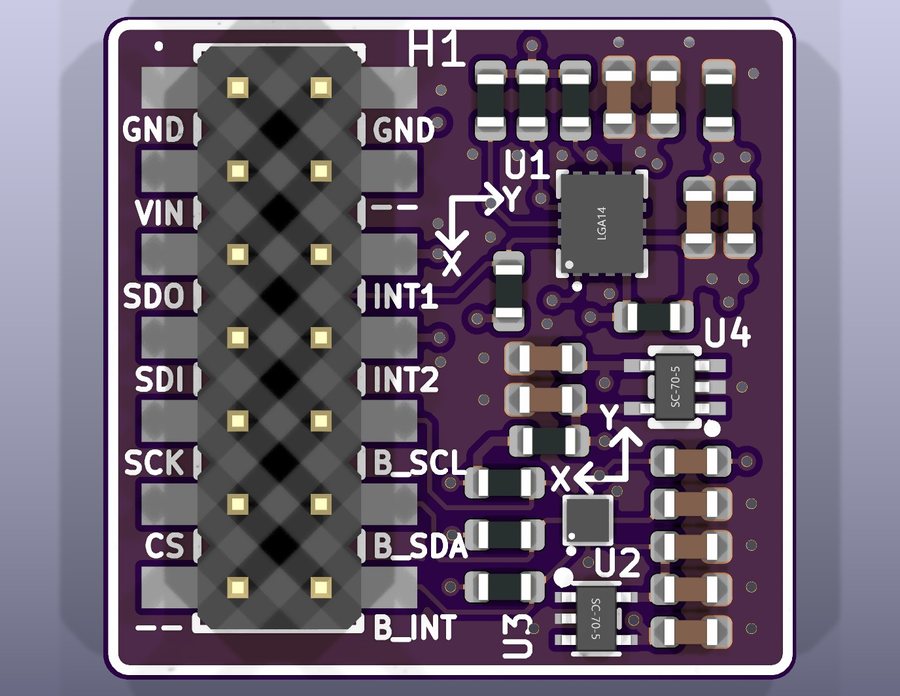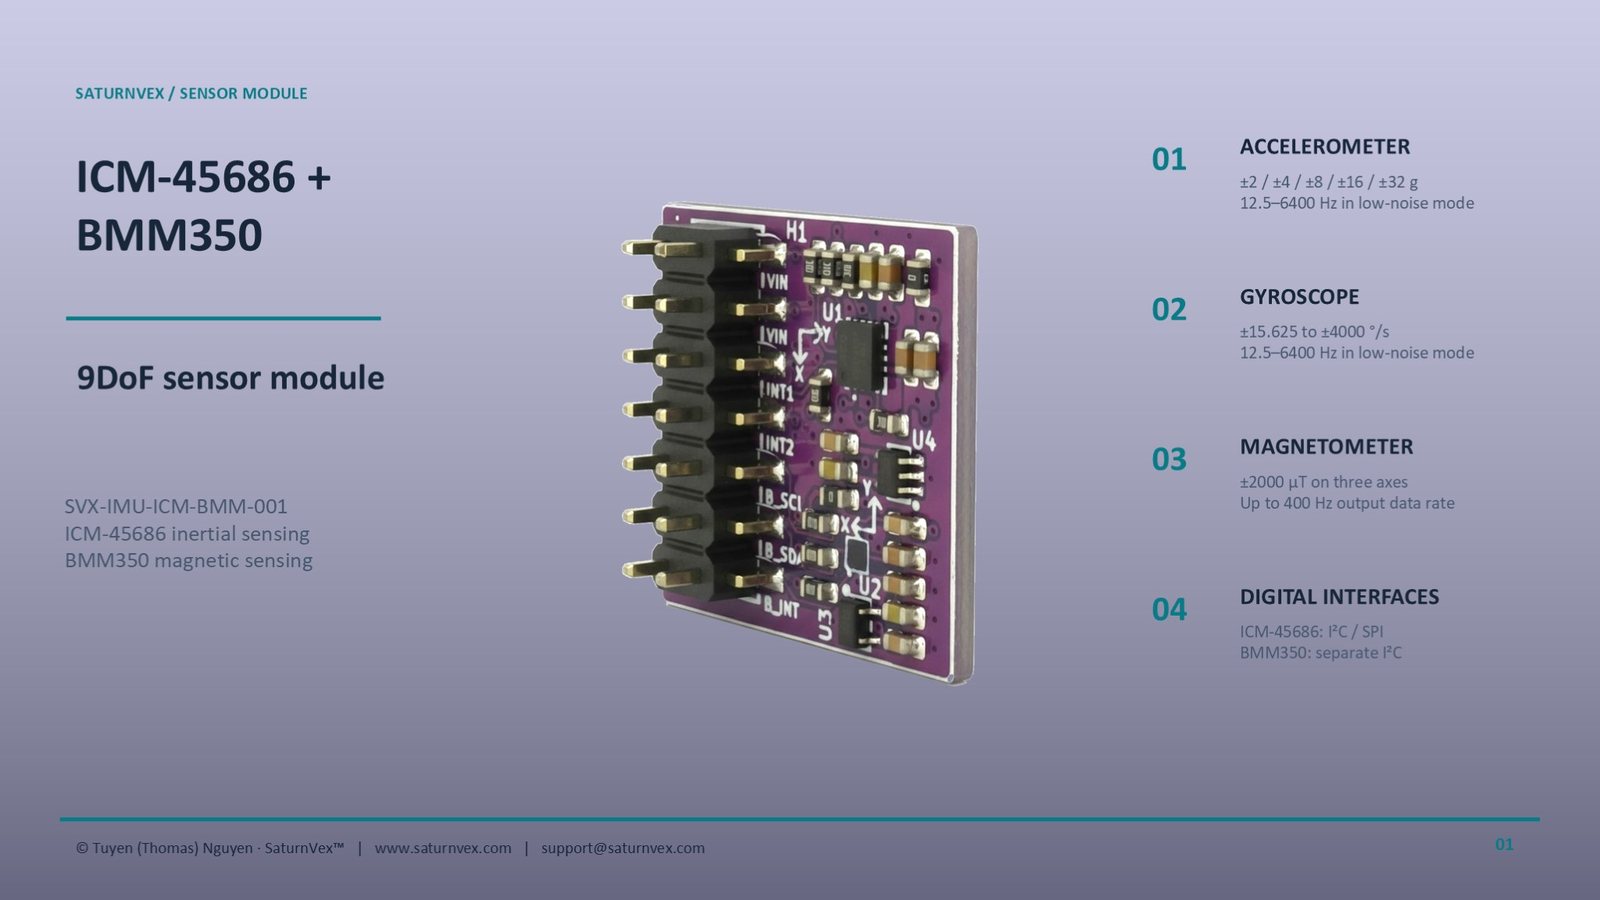
SVX-IMU-ICM-BMM-001
ICM-45686 + BMM350 9DoF Sensor Module
Compact 9DoF module with the TDK ICM-45686 six-axis IMU and the Bosch BMM350 magnetometer on one 2 × 7 header, with STM32G474 host examples for both sensors.
- ICM-45686 six-axis IMU: up to ±32 g and ±4000 °/s
- BMM350 three-axis magnetometer, ±2000 µT
- IMU on SPI or I²C, magnetometer on a separate I²C bus
- STM32G474 host examples for both sensors
Host MCU · SPI / I²C · STM32CubeIDE examples
Overview
SVX-IMU-ICM-BMM-001 gives a flight controller, robot or tracker nine axes of motion sensing on one small header: acceleration and angular rate from the TDK ICM-45686 and the magnetic field from the Bosch BMM350. The IMU connects over SPI or I²C with two interrupt lines and the magnetometer has its own I²C bus, so both can be sampled independently. The test pages show the wiring to the SaturnVex STM32G474 board and link to its ICM-45686 and BMM350 example projects.
Specifications
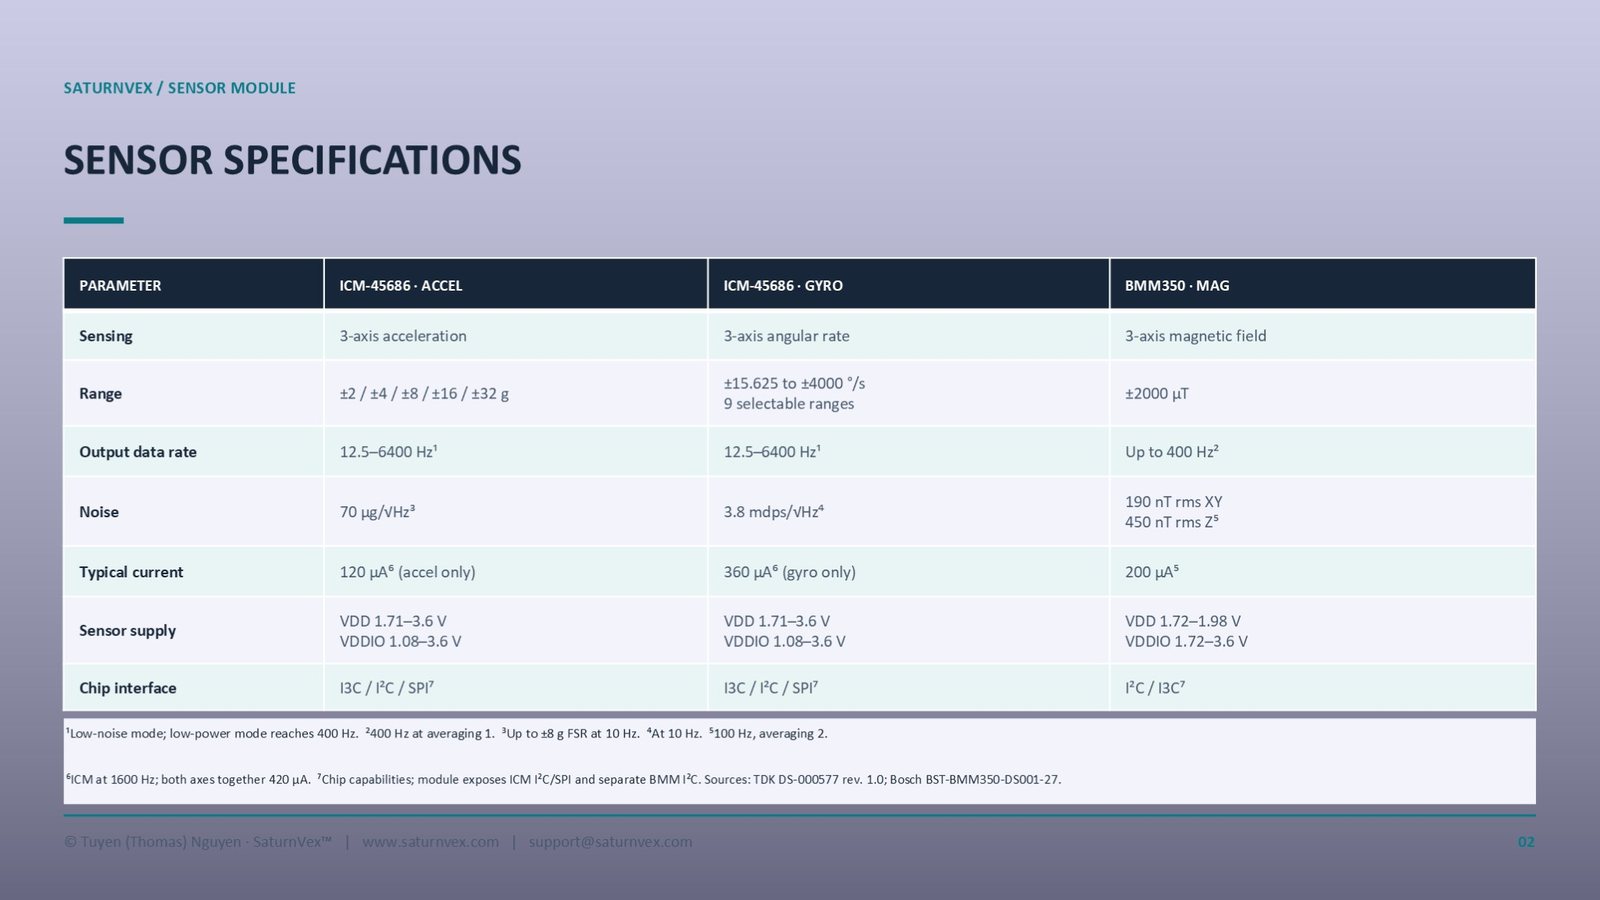
| IMU | TDK ICM-45686: accel ±2 to ±32 g, gyro ±15.625 to ±4000 °/s, up to 6400 Hz |
|---|---|
| Magnetometer | Bosch BMM350: 3-axis, ±2000 µT, up to 400 Hz |
| IMU interface | SPI or I²C, INT1 + INT2 |
| Magnetometer interface | Separate I²C (0x14) + INT |
| Connector | 2 × 7 pin 2.54 mm header |
| Power / logic | VIN 3.3–5.5 VDC, 3.3 V I/O |
| Board dimensions | About 21 × 20 mm |
Tested examples
| # | Example | Guide | Source |
|---|---|---|---|
| 01 | ICM-45686 IMU (SPI) | ||
| 02 | BMM350 Magnetometer (I²C) |
Documentation
Mechanical CAD