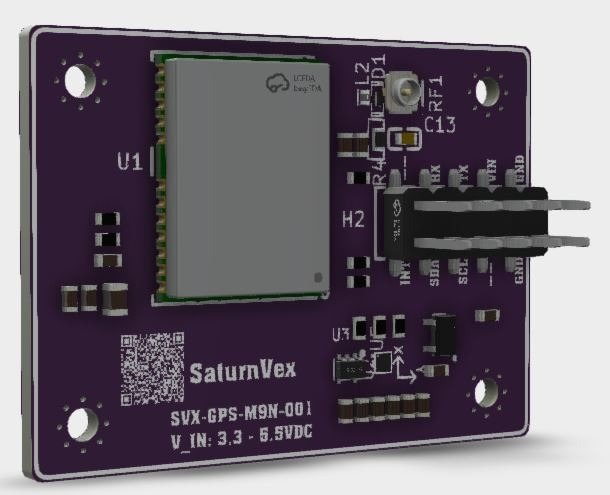
SVX-GPS-M9N-001
NEO-M9N GNSS & Compass Board
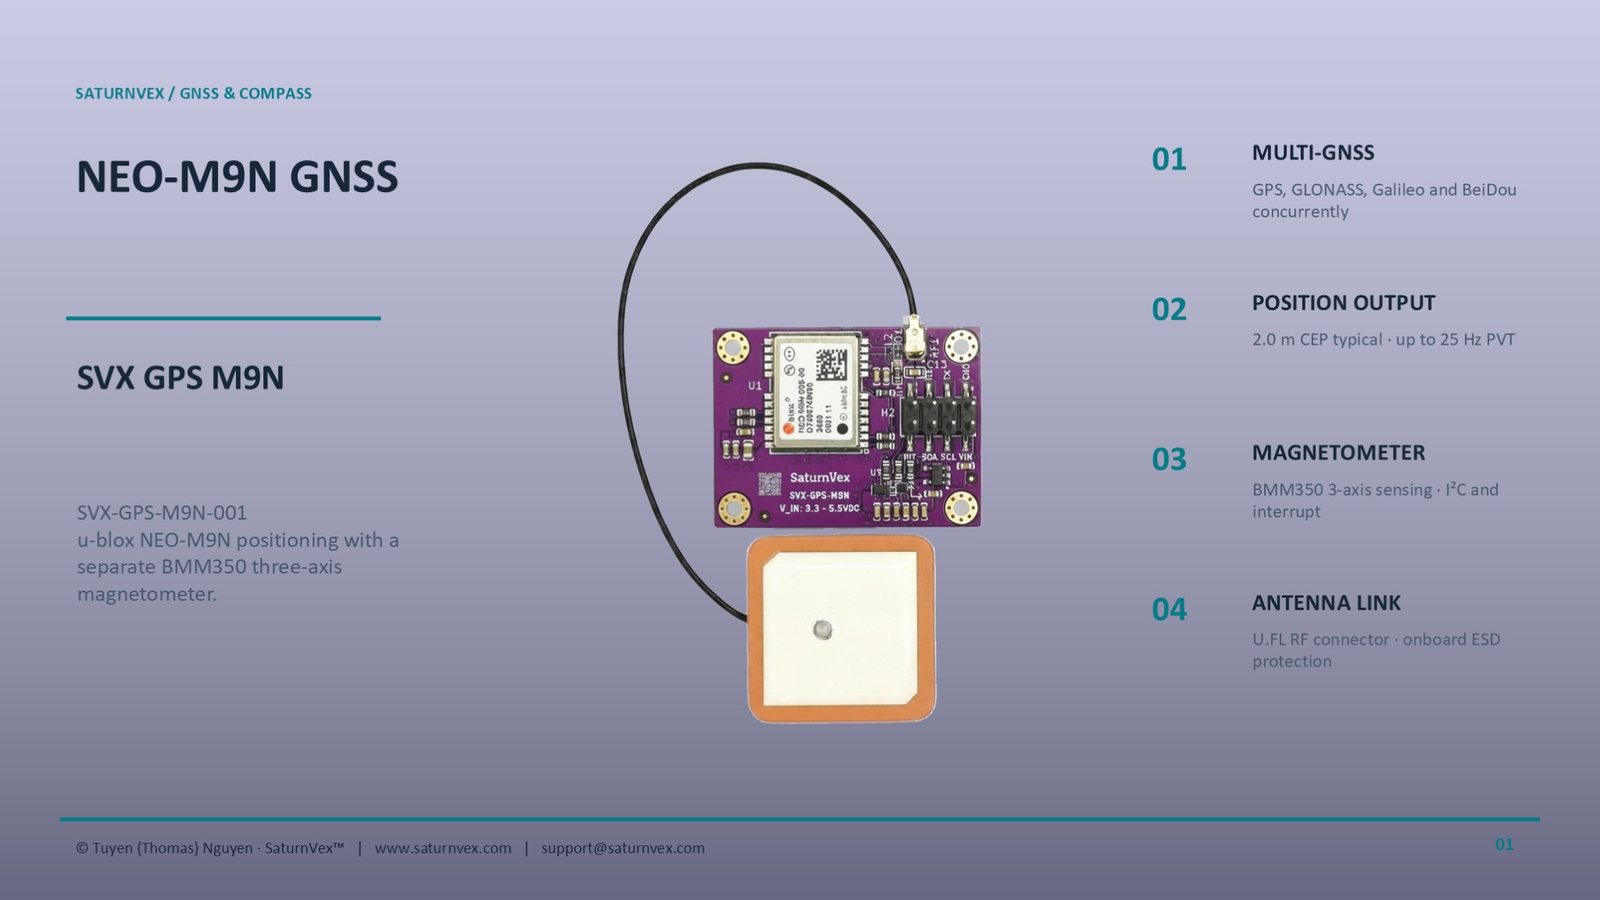
Compact multi-GNSS board with the u-blox NEO-M9N and a BMM350 three-axis magnetometer, with a Windows test tool for fix, accuracy, C/N0, TTFF and CEP measurement.
- u-blox NEO-M9N: GPS, GLONASS, Galileo, BeiDou concurrently
- 2.0 m CEP typical, up to 25 Hz navigation rate
- Bosch BMM350 three-axis magnetometer on I²C
- Windows test tool: TTFF, C/N0, DOP, CEP statistics, CSV log
- BMM350 I²C example with an STM32G474 host
Windows · Python · UART (NMEA / UBX)
Overview
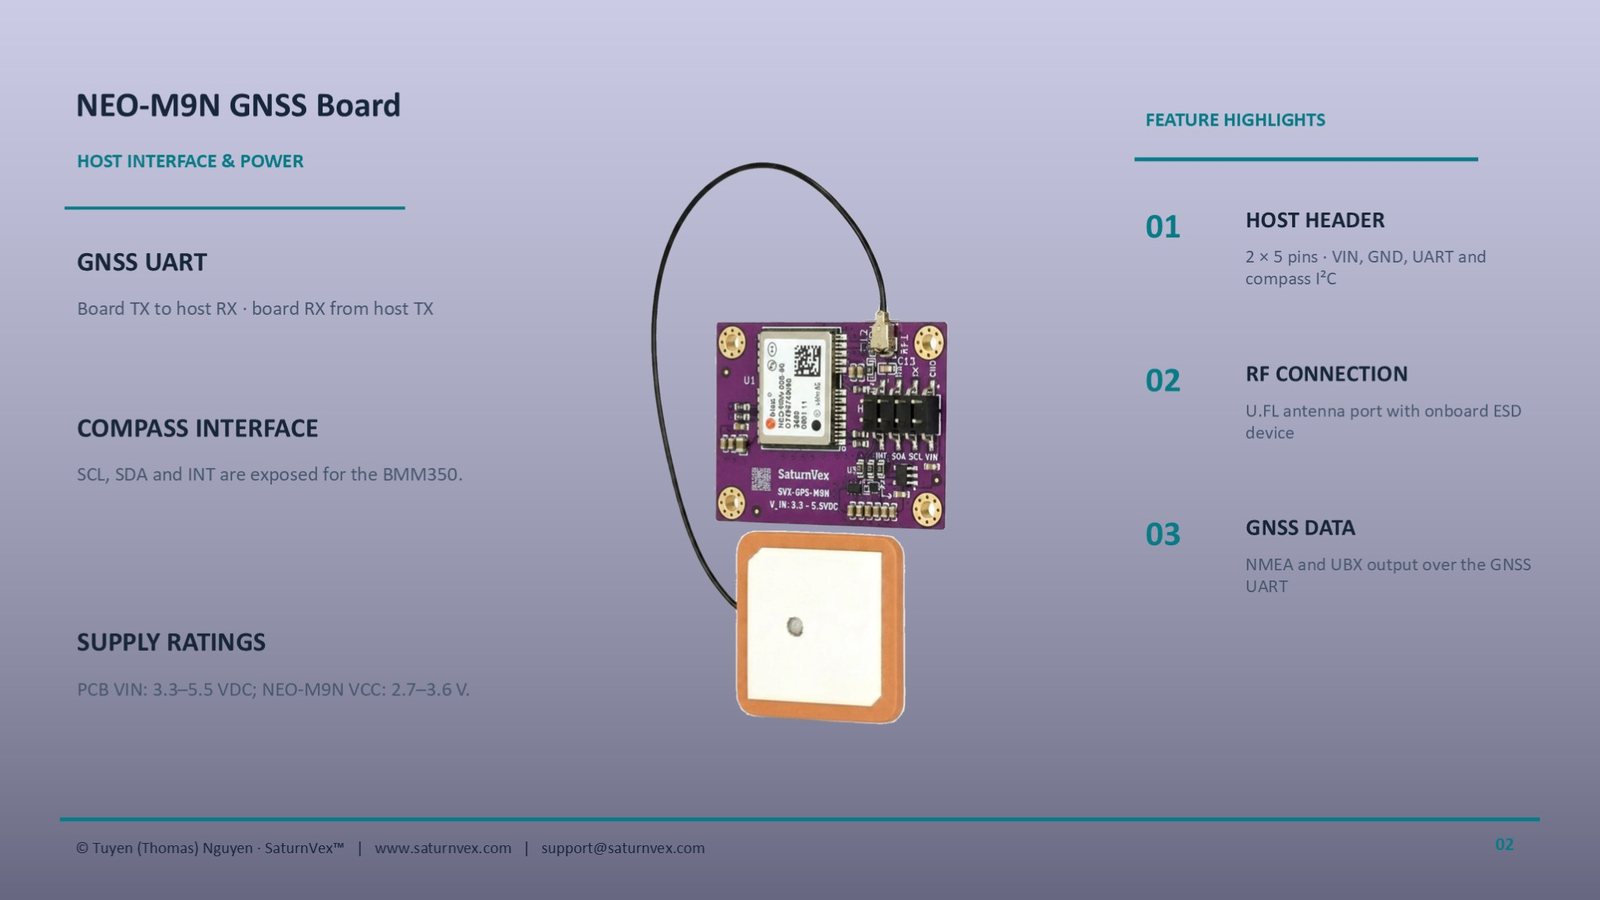
SVX-GPS-M9N-001 adds multi-GNSS positioning and a three-axis compass to UAVs, robots and trackers through one small header. The NEO-M9N outputs NMEA and UBX over a 3.3 V UART, and the BMM350 magnetometer is available on I²C with an interrupt line. The Windows test tool checks the receiver with any 3.3 V USB-UART adapter and reports fix, accuracy estimates, satellite signal strength, time to first fix and position stability, with a CSV log for the test record.
Specifications
| GNSS receiver | u-blox NEO-M9N, GPS, GLONASS, Galileo and BeiDou concurrently |
|---|---|
| Position performance | 2.0 m CEP typical, up to 25 Hz (datasheet) |
| Magnetometer | Bosch BMM350 three-axis, I²C + INT |
| Host interface | 2 × 5 header: VIN, GND, GNSS UART, BMM350 I²C / INT |
| GNSS UART | 3.3 V logic, 38400 baud default, NMEA + UBX |
| Antenna | U.FL with ESD protection and active-antenna bias |
| Power | VIN 3.3–5.5 VDC |
Tested examples
| # | Example | Guide | Source |
|---|---|---|---|
| 01 | GNSS Receiver Test Tool (Windows, UART) | ZIP | |
| 02 | BMM350 Magnetometer (I²C) |
Documentation
Mechanical CAD